Agtech · Robotics · Early stage
An autonomous robot that harvests leaf crops one ripe leaf at a time
Leaf-by-leaf harvesting is still almost entirely done by hand, and farms are running out of workers to do it. Instead of cutting the whole plant, this robot drives between the rows, finds only the leaves that are ripe, and removes them gently with a force-controlled soft stripping head. Our first pilot crop is Oriental-type leaf harvesting in Türkiye; the platform can be adapted to other crops that are harvested leaf by leaf.
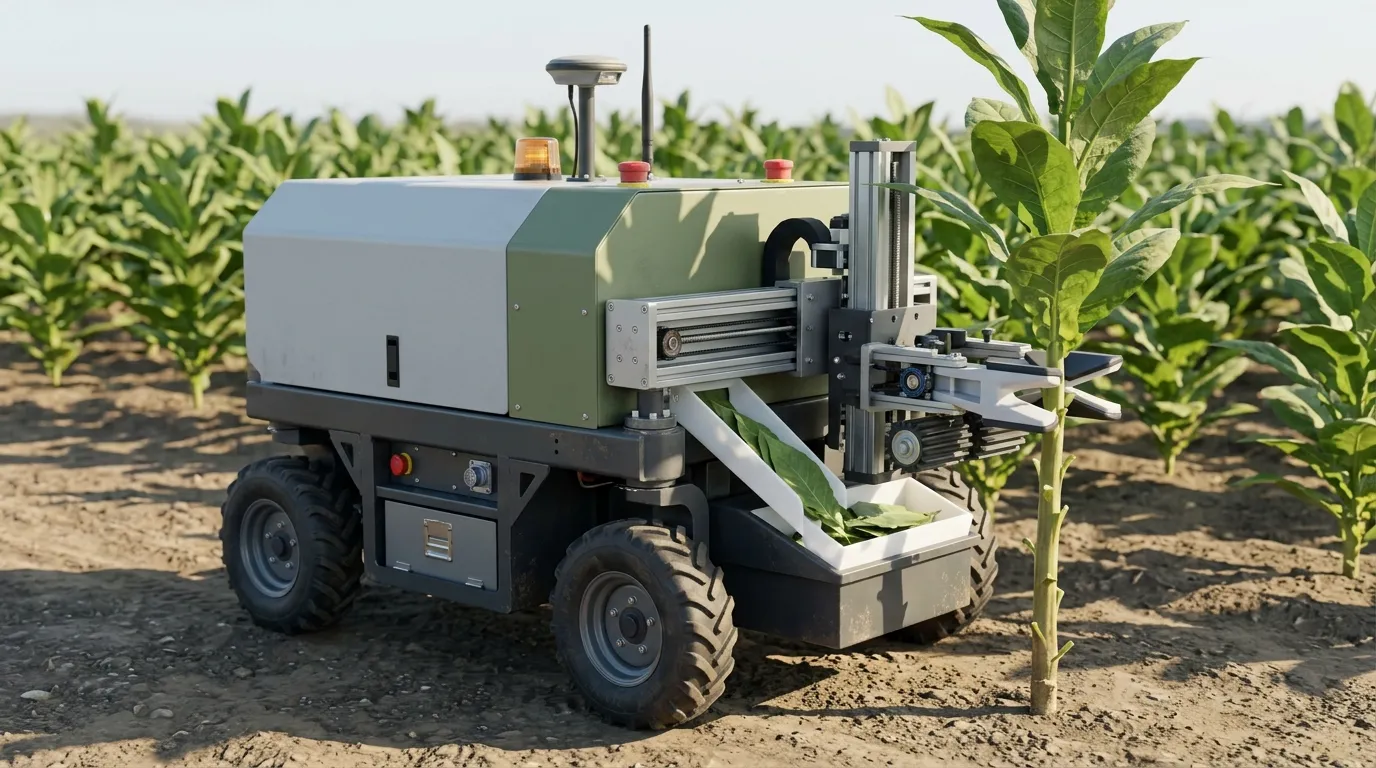
How it works
See
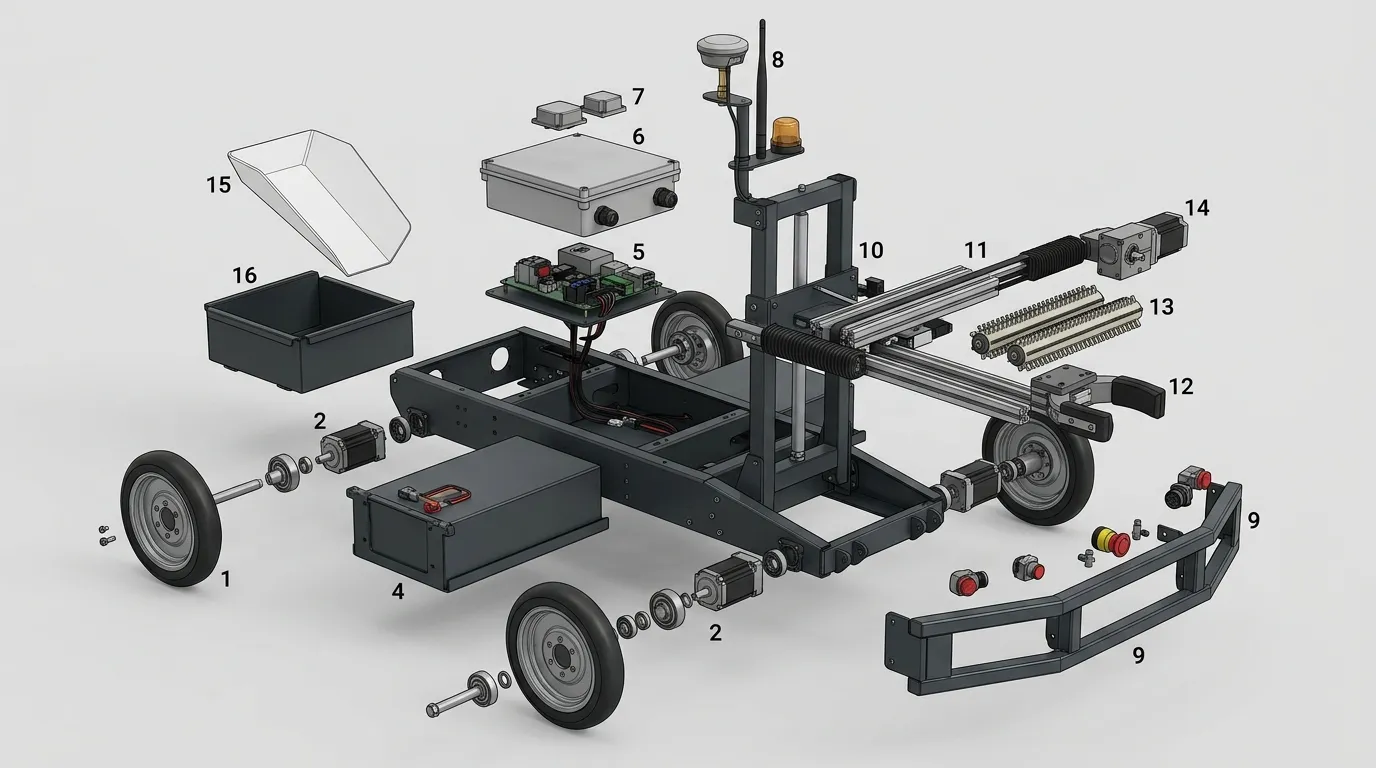
An RGB-D camera segments the stem and leaves, builds a 3D leaf band and classifies ripeness with a confidence score. A short-range ToF sensor confirms the final approach.
Pick
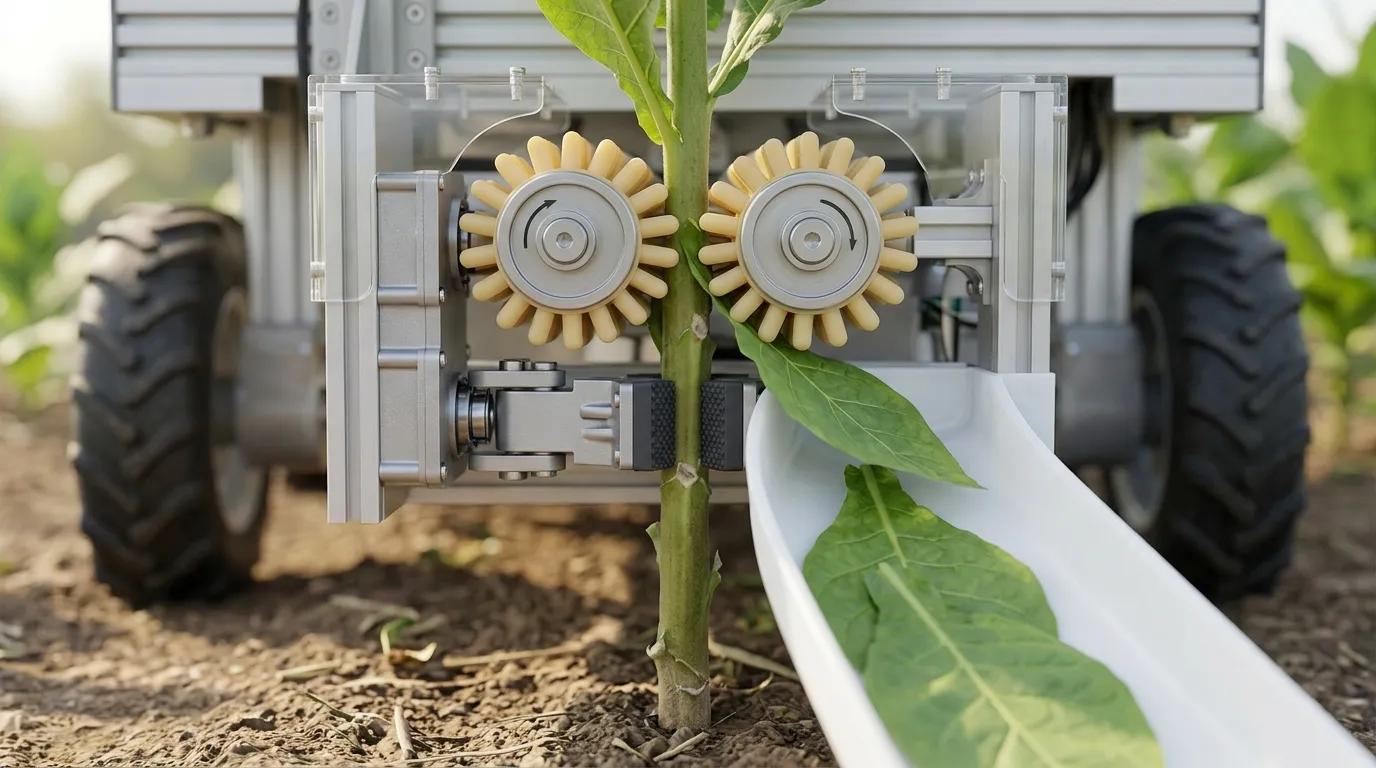
A soft-roller C-ring centers the stem; flexible elastomer fingers strip the leaf near its base with a monitored down-and-out force. If force or current exceeds the limit, the head releases and the plant is skipped.
Collect
Leaves slide down a UHMW-PE chute onto a slow soft belt and into a ventilated, swappable cassette — they never touch the ground.
Stay safe
A layered safety architecture: hardware e-stop and bumpers, MCU-level jam handling, and a supervisory computer. Designed against ISO 12100 and ISO 18497-1.
Where Claude fits
Real-time perception and motion control run on the robot. Claude does the engineering and data work around it:
- →Firmware and test-automation development for the motor and force controllers
- →QA and annotation workflows for the field image dataset (8–15k expert-labeled leaves)
- →Turning per-plant harvest logs (force, cycle time, success / skip) into reports for farmers
- →An operator and service assistant that explains alarms and guides maintenance in the field
Status & roadmap
We are a pre-incorporation team of hardware and embedded engineers. The system architecture, mechanical and power subsystem selection and safety concept are done; we are now building the P0 harvesting-head test bench. Each stage only starts once the previous gate is passed.
Field & user data
Gate: Numeric, traceable requirements
Harvesting-head test bench
Gate: ≥90% pick rate, ≤5% visible damage
Teleoperated single-arm robot
Gate: 100 m mission, 500–750 plants/h
Supervised autonomy
Gate: Test on an unseen field, zero crushed plants
Dual-arm tracked platform
Gate: ≥1,500 plants/h, quality on par with hand picking
Interested in piloting or partnering?
We are looking for pilot farms, research partners and early supporters.
contact@emirfurkansari.com